SpatialClaw accepted to NeurIPS 2026, lifts GPT-6 Astra by 6.1 points on spatial tasks
The training-free action interface SpatialClaw raises GPT-6 Astra from 71.3 to 77.4 across 20 spatial benchmarks, and the paper and code are public.
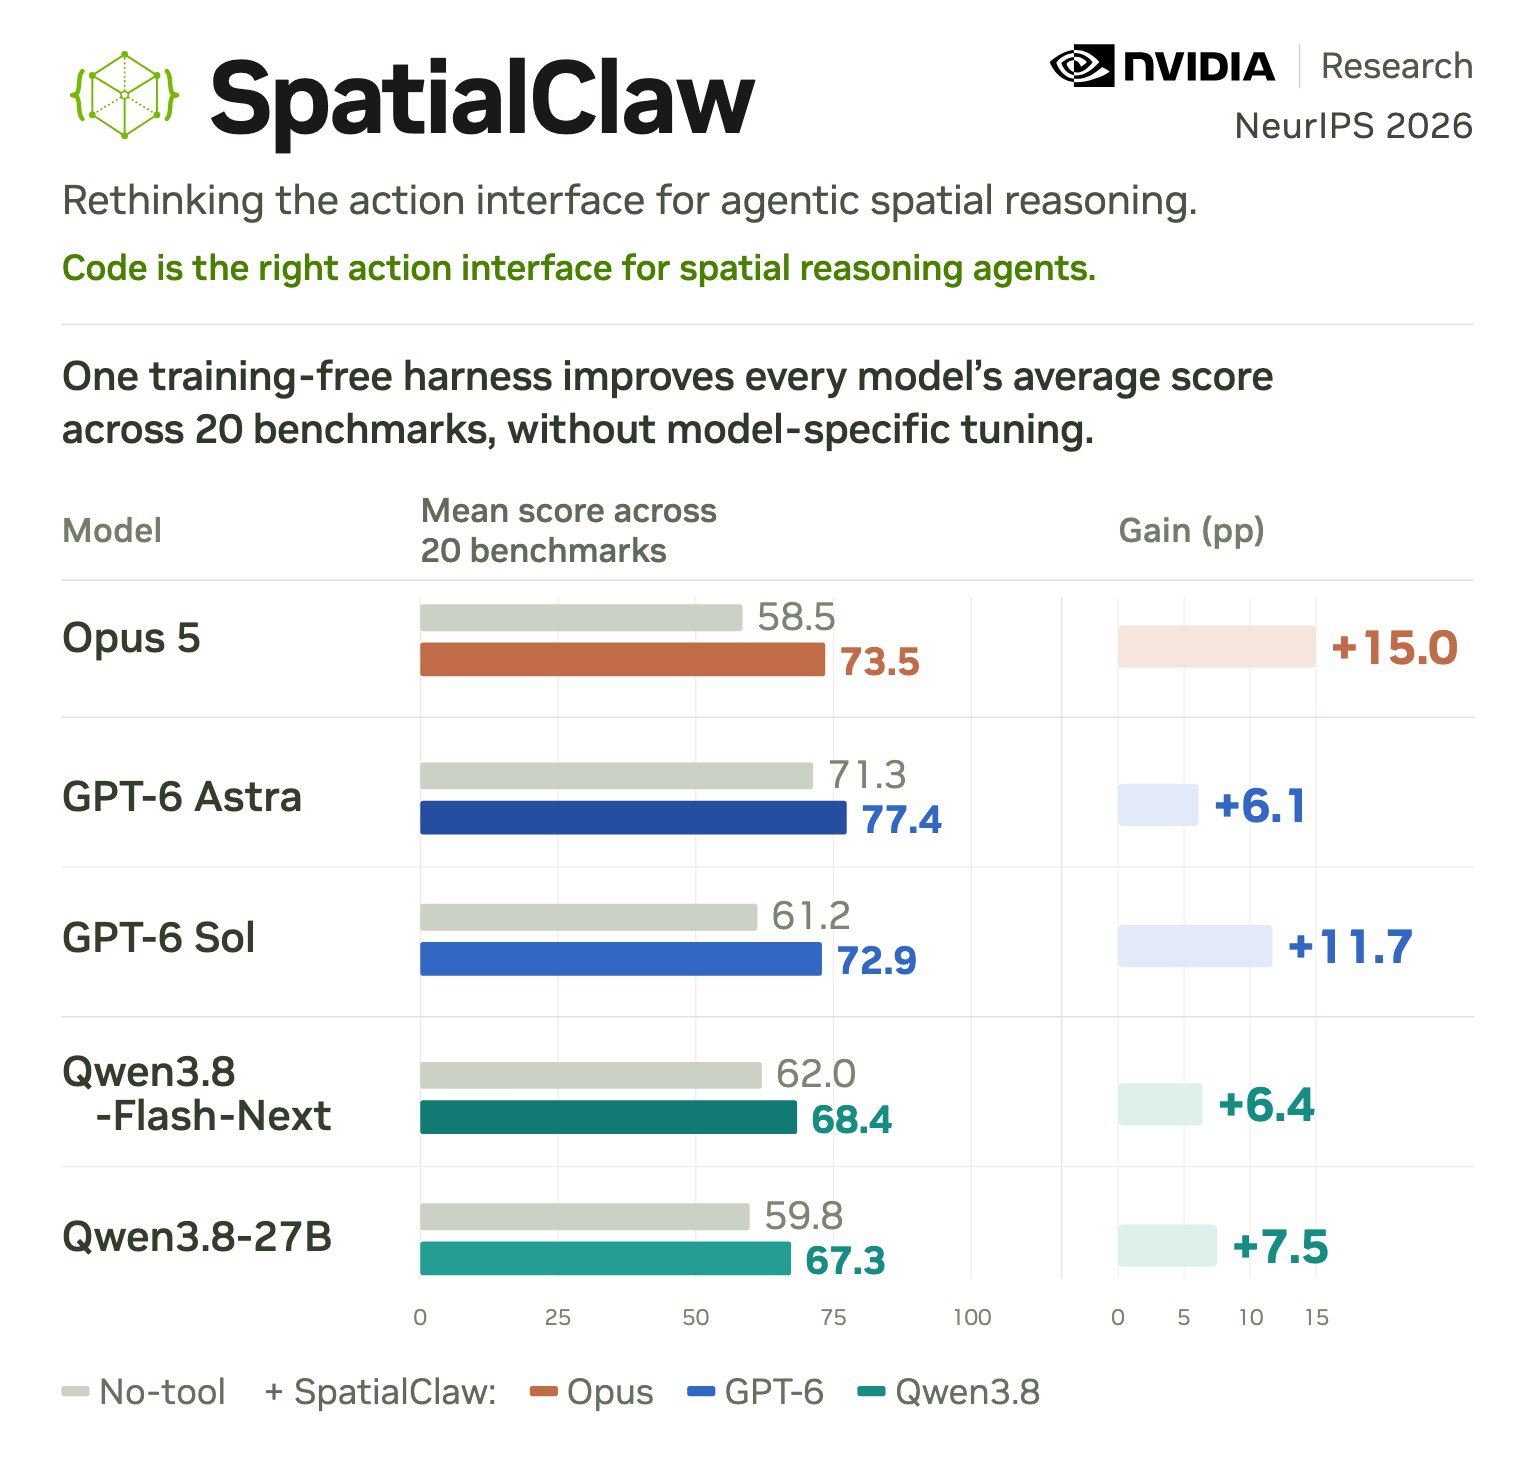
SpatialClaw accepted to #NeurIPS2026 🎉 Even GPT-6 Astra gets better with the right action interface. Same training-free harness, no model-specific tuning, 20 spatial benchmarks: GPT-6 Astra: 71.3 → 77.4 (+6.1) Opus 5: 58.5 → 73.5 (+15.0) GPT-6 Sol: 61.2 → 72.9 (+11.7) Qwen3.8-27B: 59.8 → 67.3 (+7.5) Astra already looks “spatial.” A persistent Python kernel on top of it still wins. Code is the action interface: the VLM writes one cell per step, inspects SAM / depth / geometry outputs, revises, then answers. 📄 Paper: https://arxiv.org/abs/2606.13673 💻 Code: https://github.com/NVlabs/SpatialClaw 🌐 Website: https://spatialclaw.github.io/ @NVIDIAAI