gpt-6IMAGE
Ditto-Bench tests GPT-6 Astra on complex physical robot control
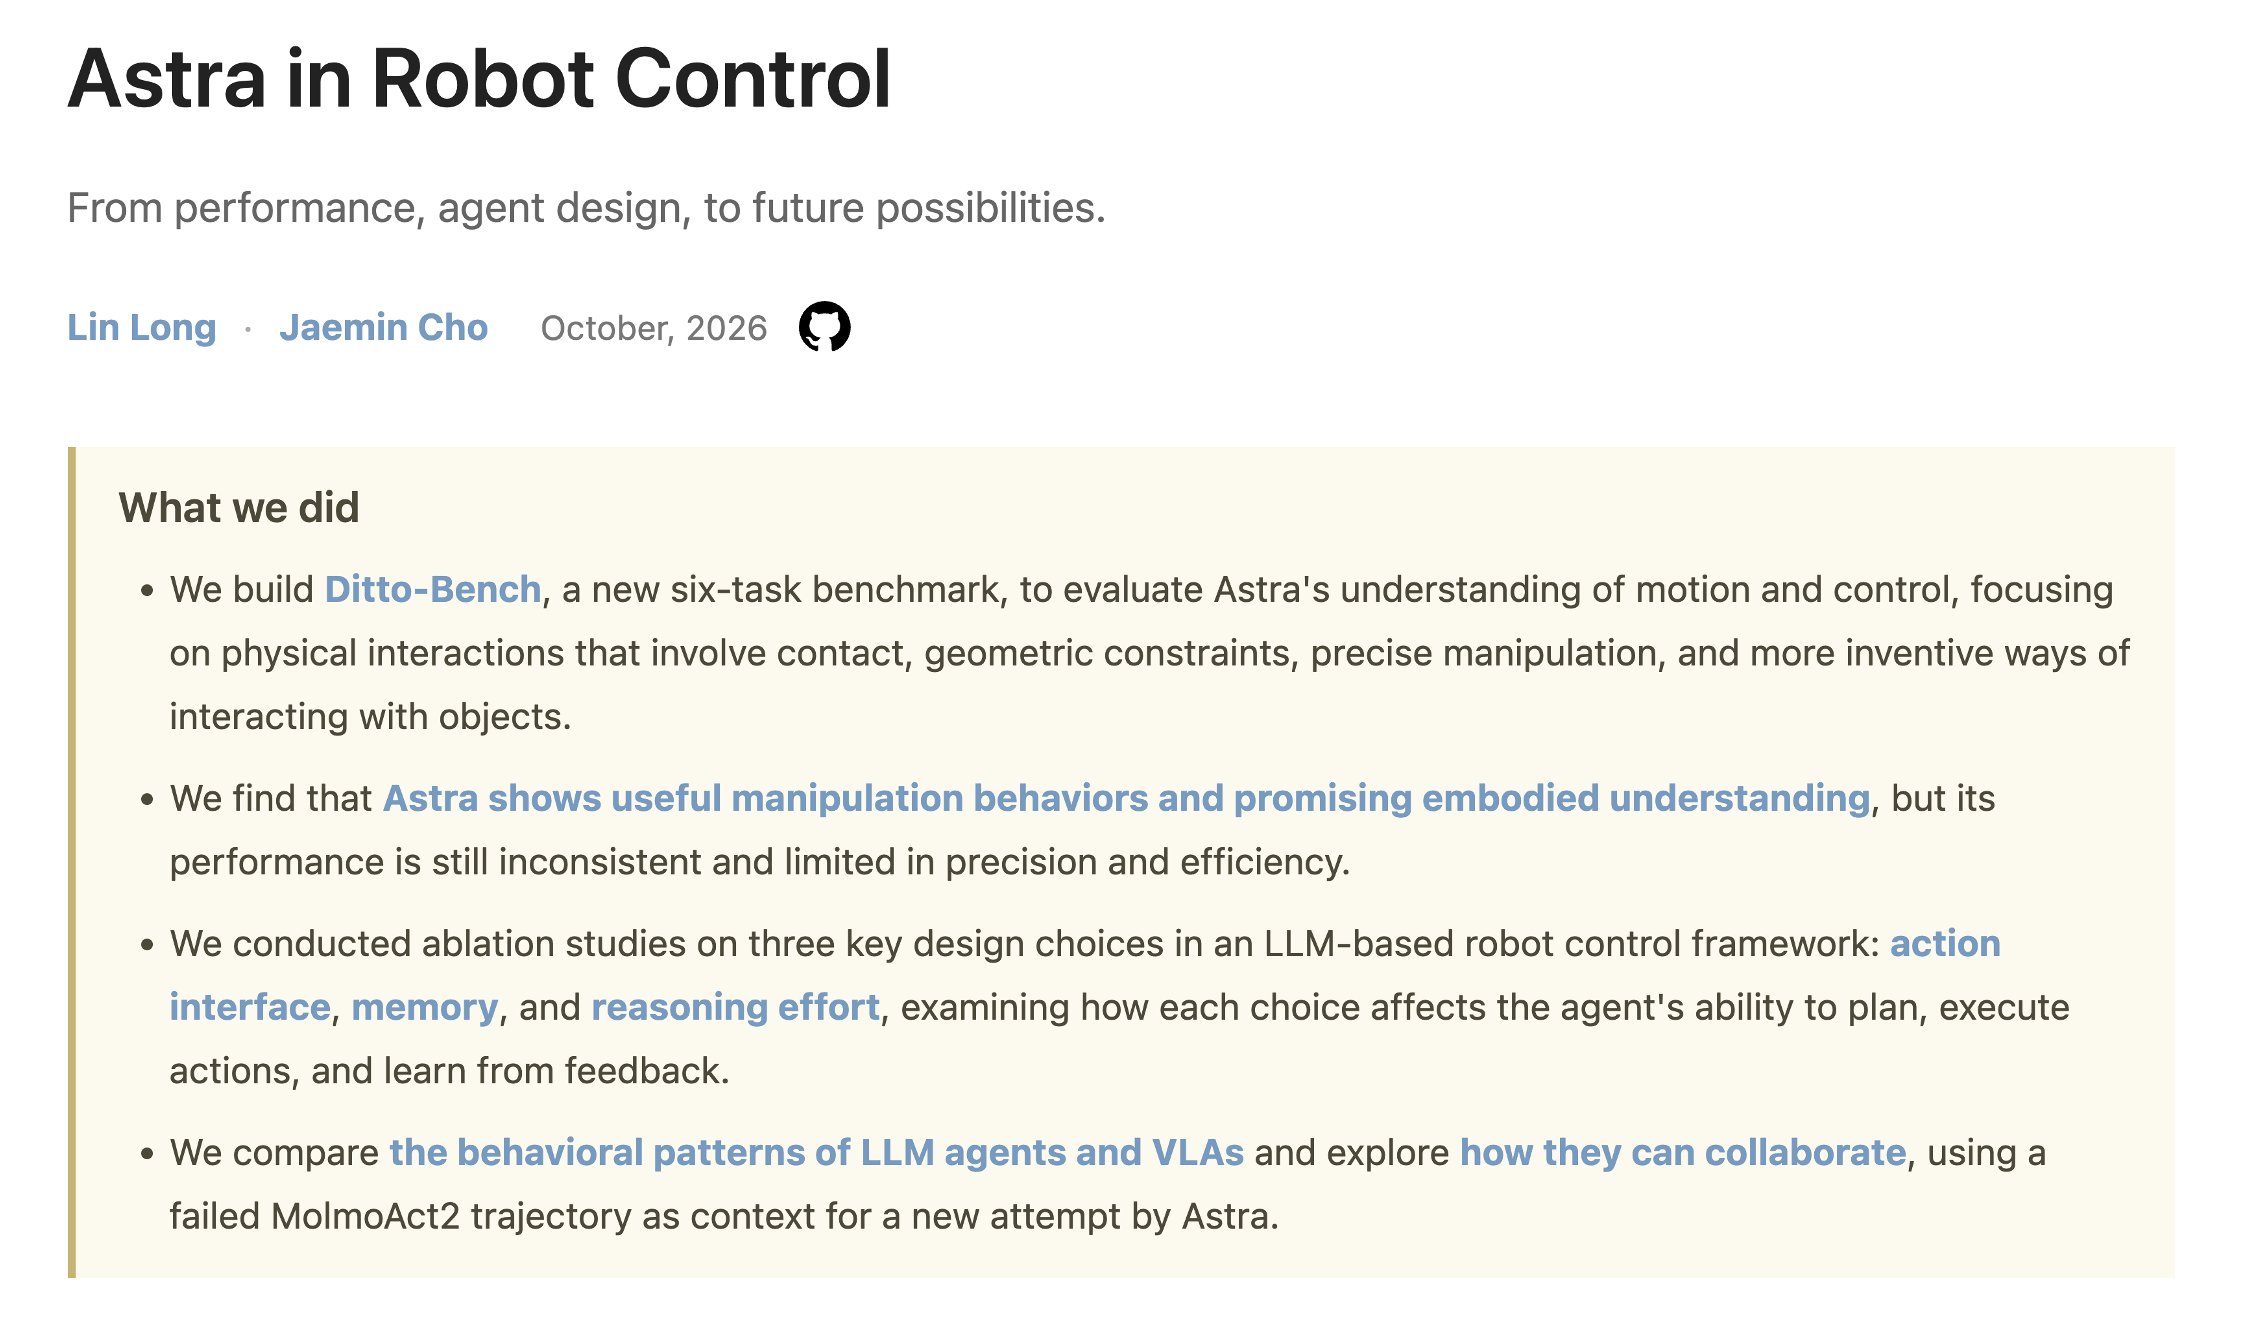
The authors built Ditto-Bench, which places simple goals inside complex physical constraints, to compare GPT-6 Astra and MolmoAct2 on robot control.
Lin Long
@Kylin_0LongArchived 24 days agoOriginally posted 2026.10.09
Lin Long @Kylin_0LongOriginally posted 2026.10.09
GPT-6 Astra has shown impressive results in simple robot control tasks. But what if the tasks become more challenging and involve complex geometric constraints, precise contact, or improvised tool use? To find out, we: - Built Ditto-Bench, where simple goals meet challenging physics, and tested both Astra and MolmoAct2. - Systematically ablated key design choices to understand what makes these robot-control agents succeed, or get stuck. - Explored what new possibilities these models could open up for robotics, such as in-context learning. More details 🧵👇
x.com/kylin_0long/status/2108292995678347492Archived 2026.10.09 10:38