Gemini 4 Argon demo builds robot sims from one photo
Google's blog says one tabletop photo becomes a simulation twin running 4,500+ randomized episodes, lifting real-robot success from 56% to 75% and cutting time from 35s to 24s.
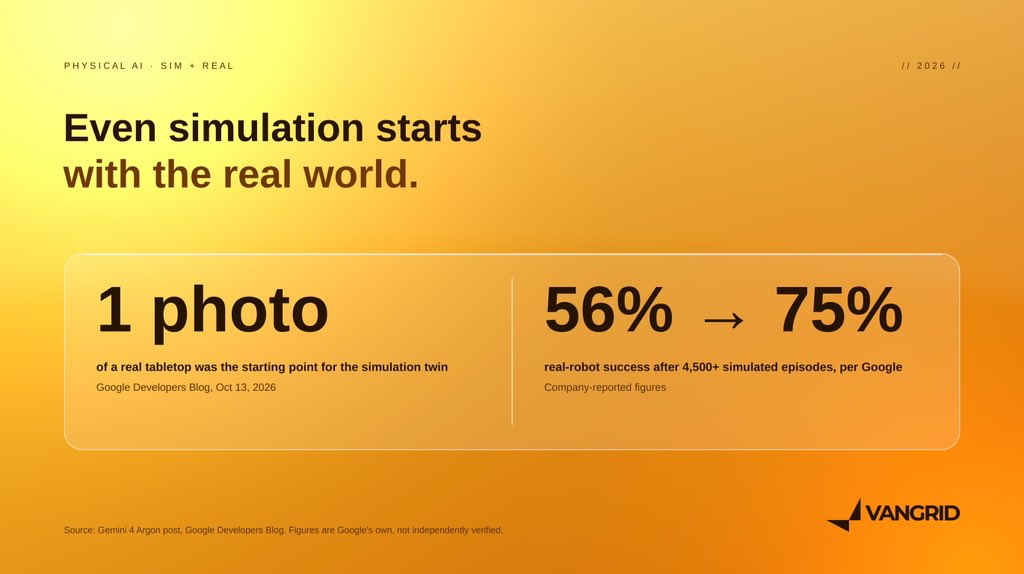
Google’s Gemini 4 Argon post has a demo I keep thinking about. Starting from one photo of a real tabletop, it builds a simulation twin and runs 4,500+ randomized episodes. Google says real robot success went from 56% to 75%, and completion time from 35s to 24s. Those are Google’s own numbers from its blog. Synthetic data is clearly getting better. But look at where that pipeline starts: a capture of a real place. The post also lists real inputs like robot camera feeds and egocentric human video. That’s the layer @vangrid_io works on: real captures of real places, with provenance you can check.