jevIMAGE
23M 参数 Jev 机器人决策模型,7ms 推理
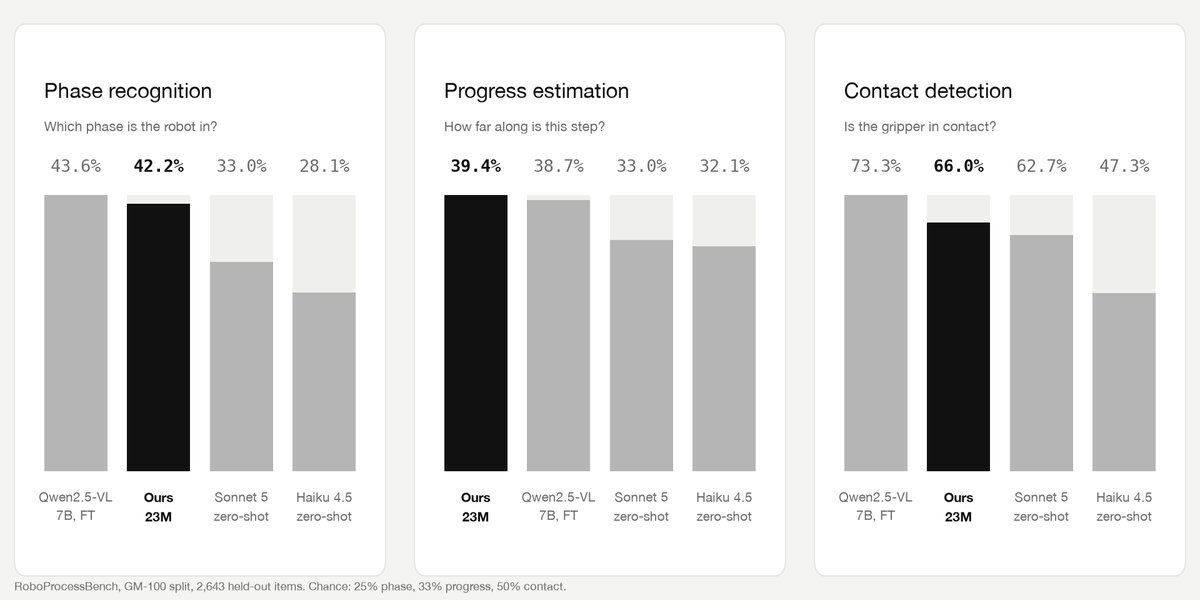
作者用 Jev 思路做了机器人实时阶段追踪模型,7ms 推理比 SOTA 快 25 倍,在 RoboProcessBench 上追平大 300 倍的 VLM。
Belusochim Ugochukwu
@belusochim2026.10.03收录原推发布于 2026.10.03
Belusochim Ugochukwu @belusochim原推发布于 2026.10.03
I built Jev for robotics. It’s a 23M parameter model for real-time phase tracking and subtask monitoring. - 7ms inference (25× faster than the current SOTA) - On par with a 300x bigger VLM on RoboProcessBench eval Designed to give policies fast, reliable progress signals without heavy compute overhead. More info here 👇🏽
x.com/belusochim/status/2106134977251549628采集于 2026.10.03 10:02