gpt-6IMAGE
SpatialClaw 被 NeurIPS 2026 接收,Astra 空间任务提升 6.1 分
免训练动作接口 SpatialClaw 让 GPT-6 Astra 在 20 个空间基准上从 71.3 升到 77.4,论文与代码已公开。
Min-Hung (Steve) Chen
@CMHungSteven2026.09.30收录原推发布于 2026.09.29
Min-Hung (Steve) Chen @CMHungSteven原推发布于 2026.09.29
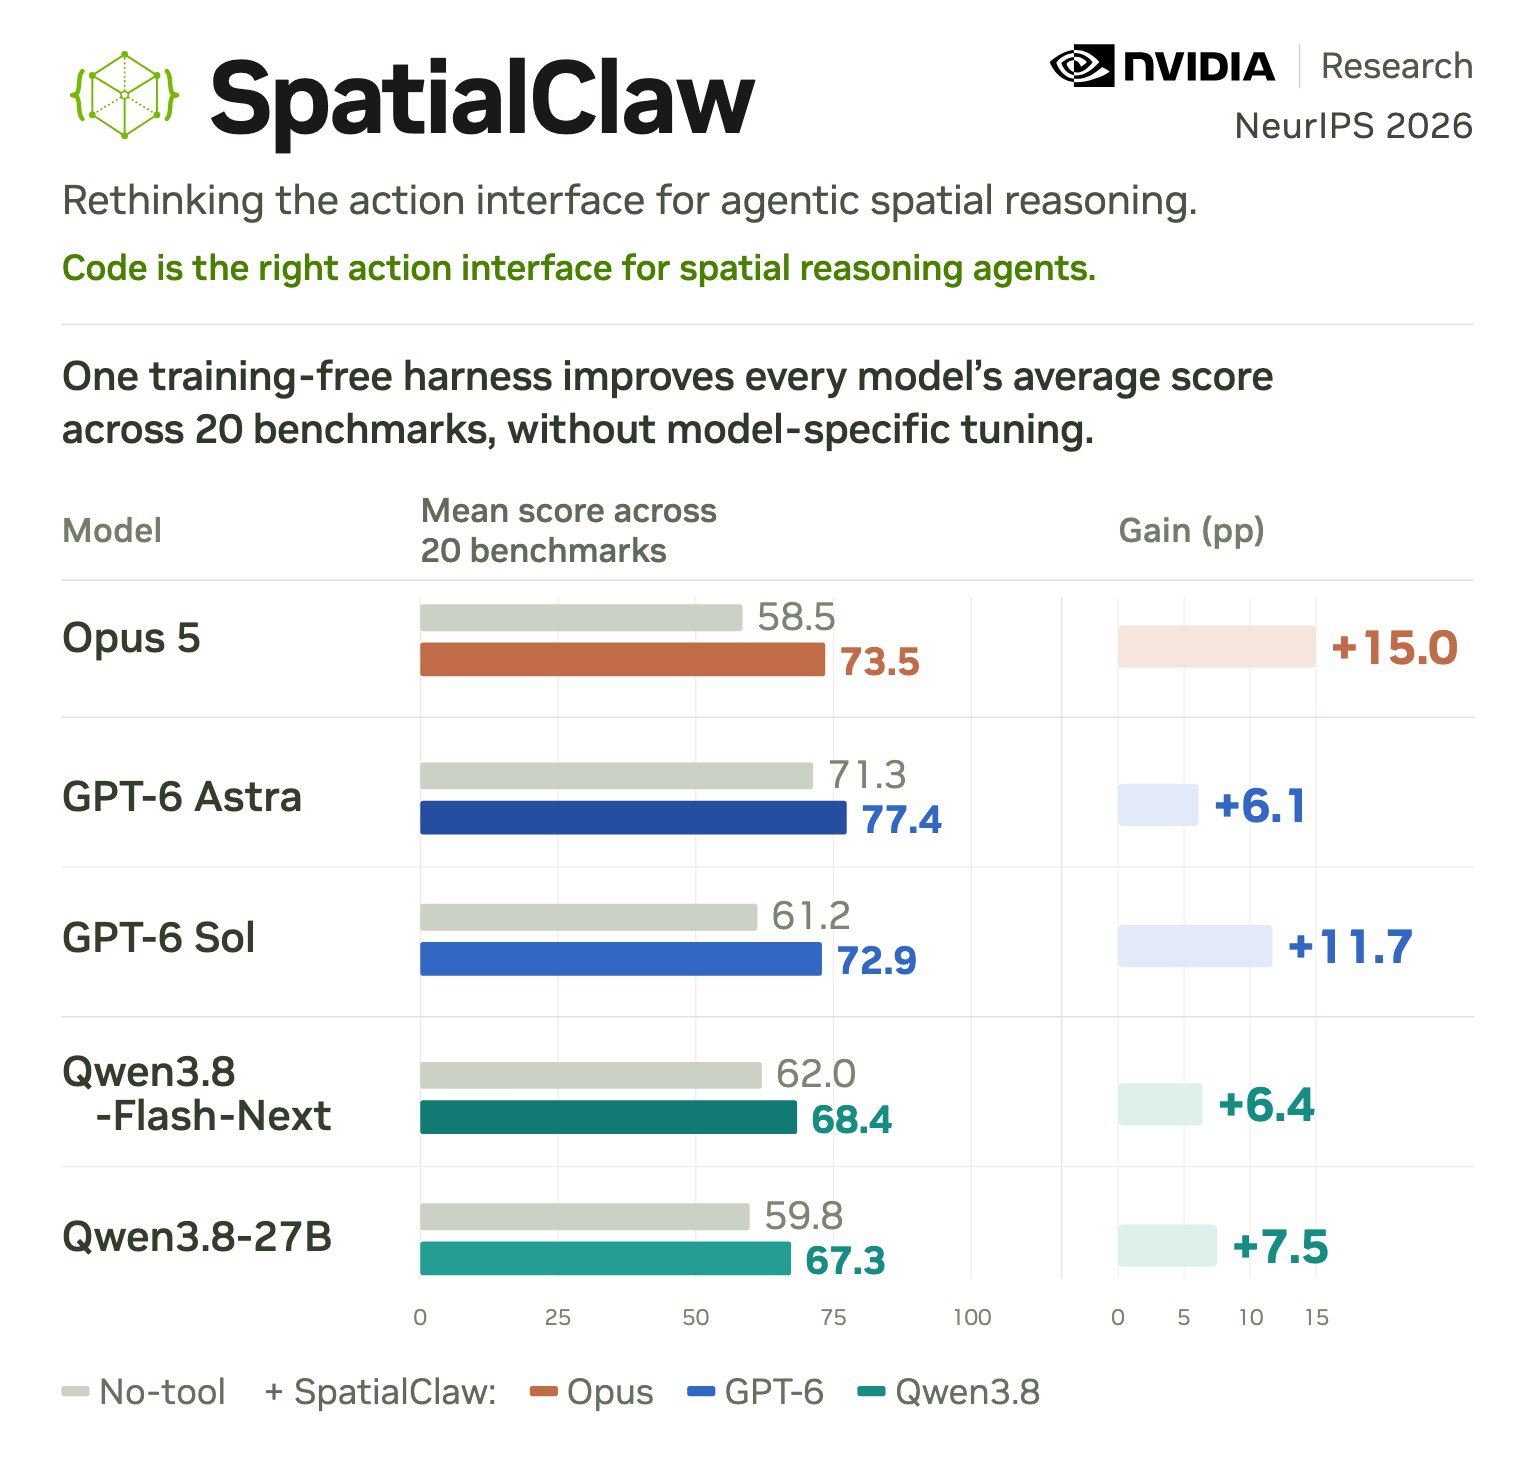
SpatialClaw accepted to #NeurIPS2026 🎉 Even GPT-6 Astra gets better with the right action interface. Same training-free harness, no model-specific tuning, 20 spatial benchmarks: GPT-6 Astra: 71.3 → 77.4 (+6.1) Opus 5: 58.5 → 73.5 (+15.0) GPT-6 Sol: 61.2 → 72.9 (+11.7) Qwen3.8-27B: 59.8 → 67.3 (+7.5) Astra already looks “spatial.” A persistent Python kernel on top of it still wins. Code is the action interface: the VLM writes one cell per step, inspects SAM / depth / geometry outputs, revises, then answers. 📄 Paper: https://arxiv.org/abs/2606.13673 💻 Code: https://github.com/NVlabs/SpatialClaw 🌐 Website: https://spatialclaw.github.io/ @NVIDIAAI
x.com/cmhungsteven/status/2104922895621165281采集于 2026.09.30 10:22