Frame Robotics 把 Jev 当作机械臂决策闸门
机器人团队评估用 LLM 当大脑、Jev 当闸门:Jev 不写计划也不动关节,只对「抓取还是中止、重试还是保持、接触是否够稳」给出带概率的选择与分数,作者也点出它看不到摄像头、不能当安全层。
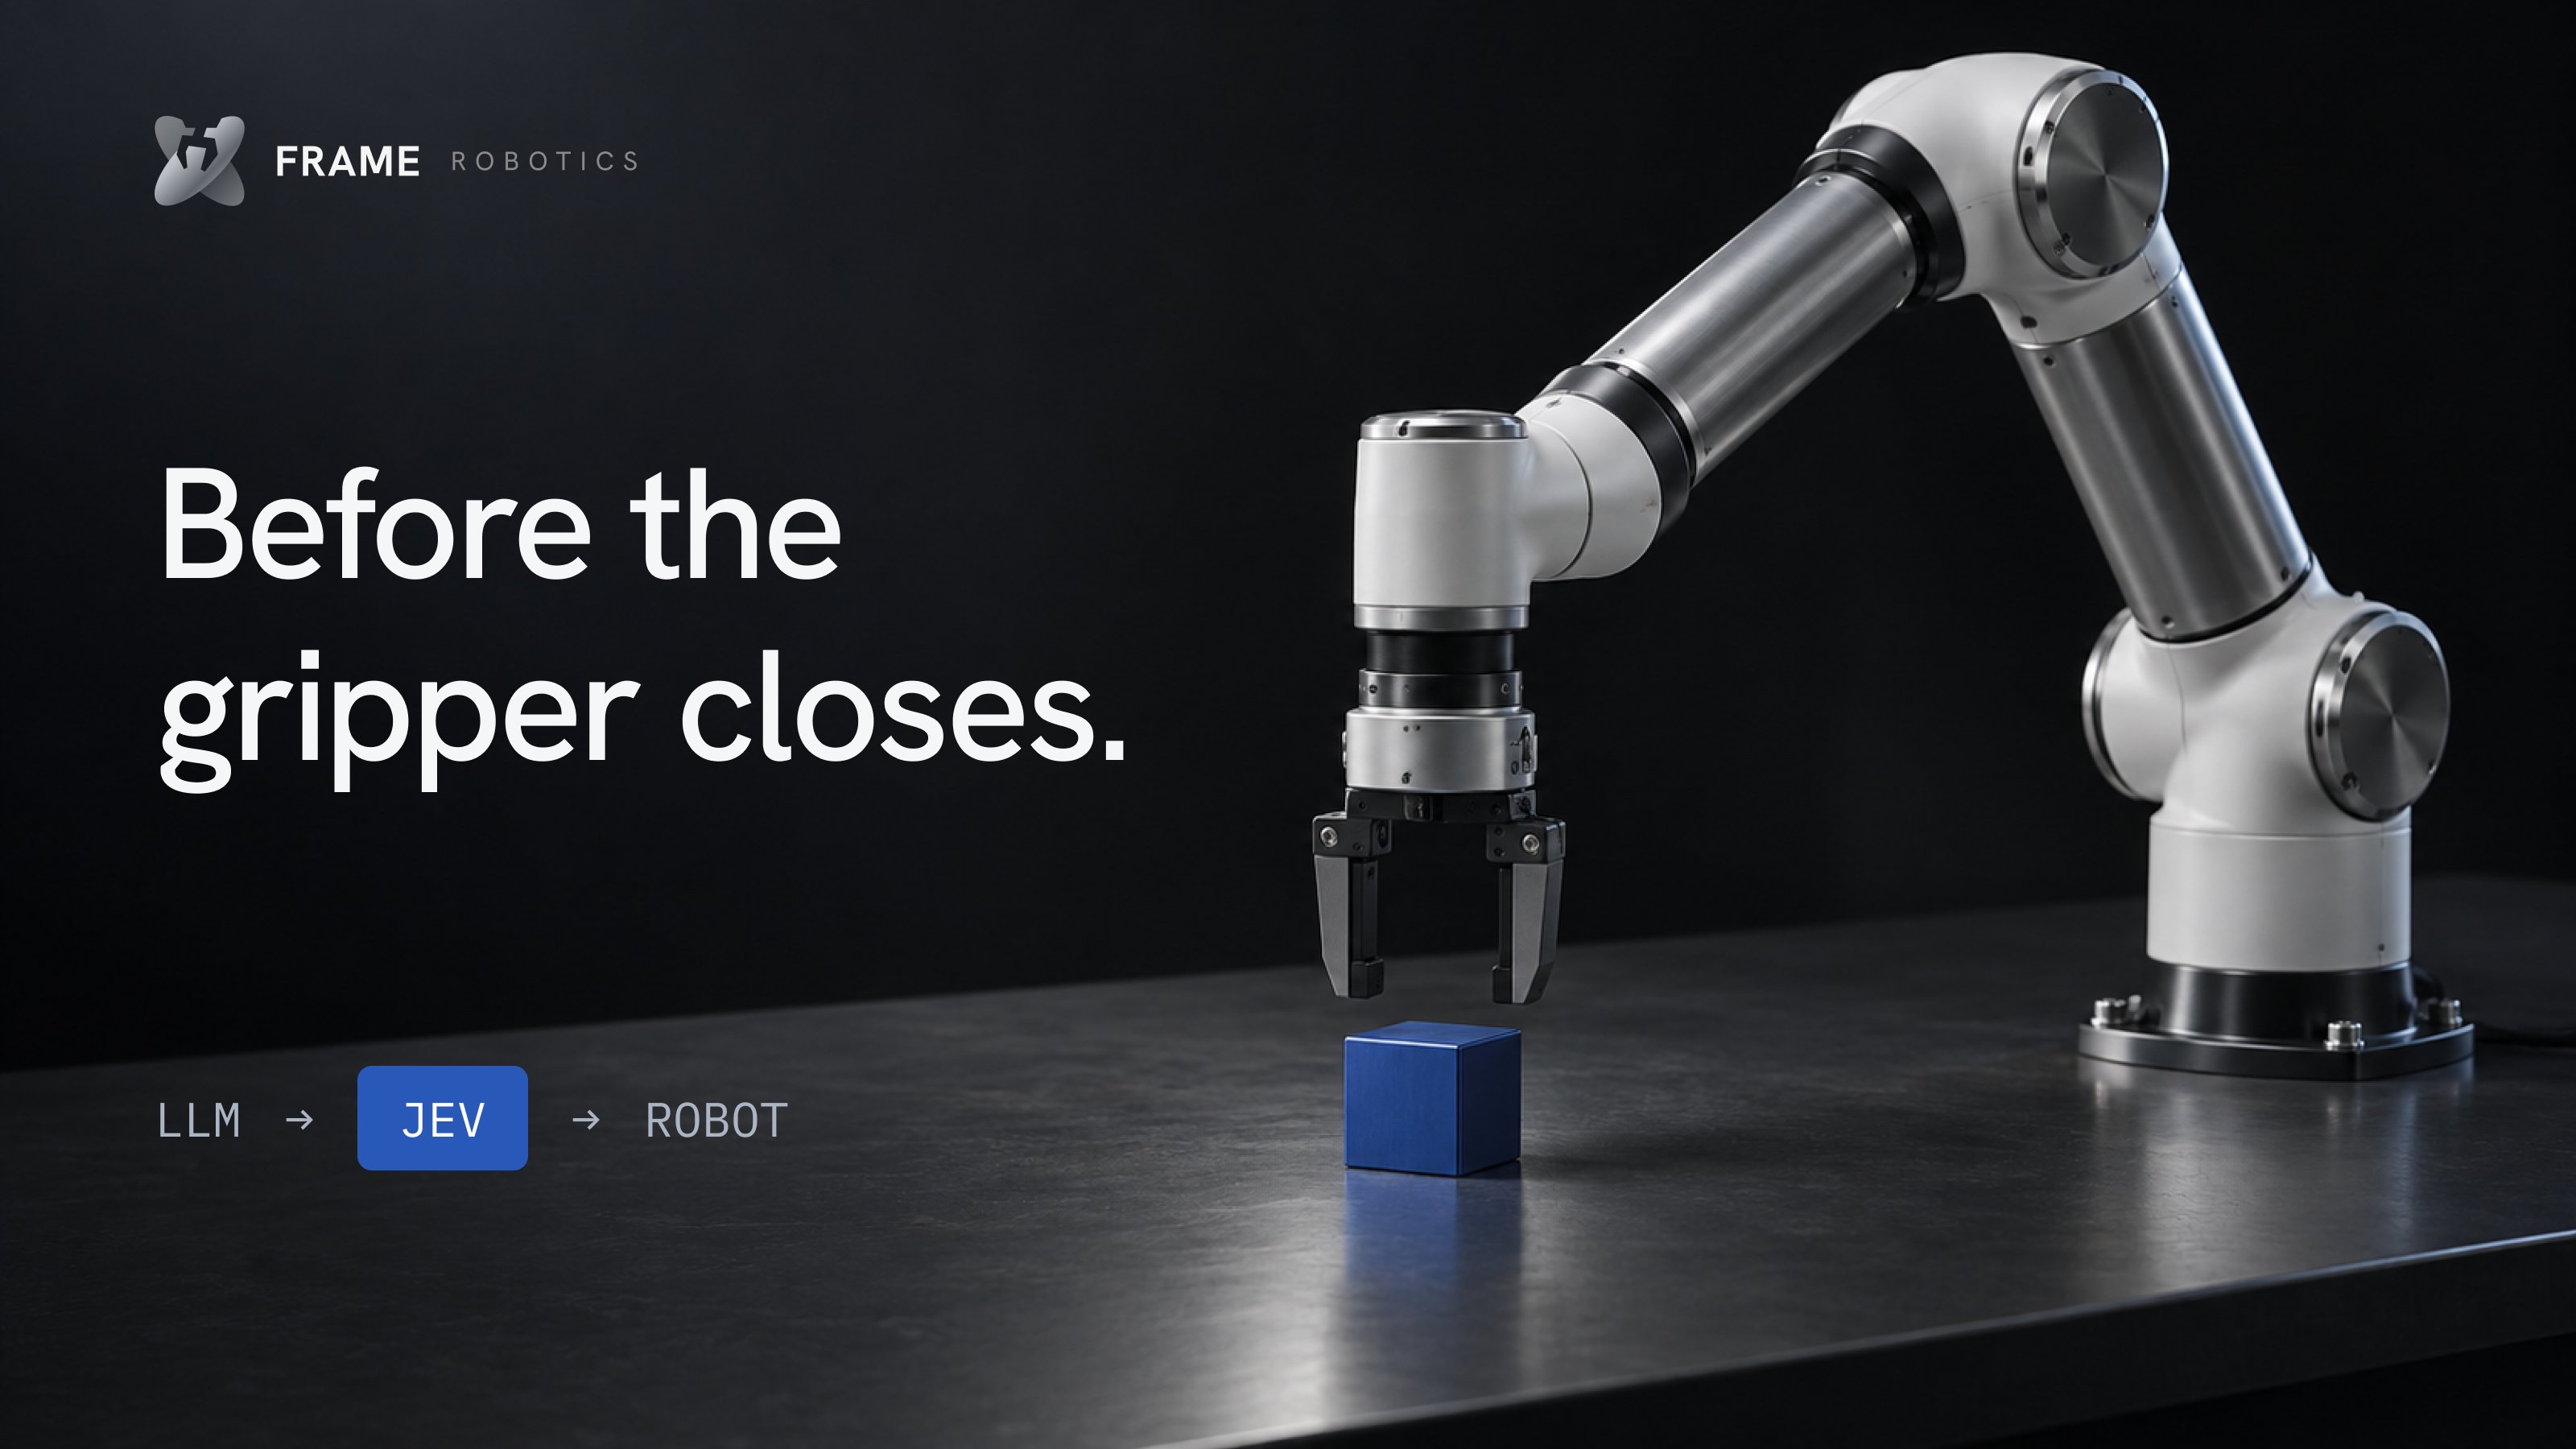
We're taking a closer look at JEV. The split we already wanted looks like this. A language model as the brain. A decision model as the gate. The llm reads the task, the demo, the scene. Jev does not write a plan and it does not move joints. It scores the next commit. Grasp or abort. Retry or hold. Is this contact stable enough to keep going. That stack is technically real. Slow layer proposes. Fast layer votes. Controller runs the arm. Jev is the vote in a form software can consume. A choice, a score, a yes or no, with a probability. Cheap enough for the decision loop. Not the 1khz loop. That still belongs to the hardware. Jev cannot see a camera. Your code has to turn the scene into state first. It cannot be the safety layer. If confidence is low, you stop in code. There is still a lot of work. Test it on real ticks. Measure whether 80% confident is actually right 80% of the time on your robot. Perception, rates, fallbacks, what happens when the scene dump is wrong. None of that is done. JEV-class models in robotics are still promising. Worth the research time. Because the gate between "the model said pick" and "the gripper closed" finally has a shape you can afford to call.